Robotics RoboCup JR Rescue Maze
RoboCup Junior Rescue Maze: from school robotics to a single-board UNO Q platform
Quick access
RoboCup is a physicalroboticsplatform, not a public web application.
RoboCup JuniorRescue Maze is the FermiLabs robotics project dedicated to building, testing and understanding autonomous rescue robots. We have worked on this specialty since 2025, combining competition experience with a long-term engineering path that connects robotics, electronics, embedded software, Linux, artificial intelligence, mapping and measurement.
Our 2025 starting point
The story began in 2025 as a school project based on LEGO SPIKE. That first platform gave the team a practical entry point into rescue-maze strategy, sensor placement, programming, teamwork and competition discipline. The school team reached the European podium in 2025 and confirmed its European-level performance at the 2026 event.
Alongside the school platform, FermiLabs developed an independent 2025–2026 engineering track. The two paths are related by the experience gained in the competition, but they are not the same hardware project: the FermiLabs platform was created to investigate a more open, measurable and reproducible robotics architecture.
The 2025–2026 FermiLabs transition
AfterMaker Faire Rome2025 and the collaboration withArduino, FermiLabs started a new hardware and software direction for the 2025–2026 cycle. The first architecture combined anArduino GIGA R1with anArduino UNO Q: the GIGA provided a real-time control base, while the UNO Q introduced a Linux-capable platform for perception, tools and advanced integration.
We then pushed the design further with QB8, our 2026 robot concept built around a single Arduino UNO Q board. The goal was to take the UNO Q to its practical extreme: one compact platform hosting the robot control software, transport integration, sensing coordination and Linux-side engineering tools, rather than hiding complexity behind several unrelated controller boards. QB8 is our concrete demonstration of how far a single UNO Q can be taken in a Rescue Maze robot when the hardware and software boundaries are designed together.
2026 competition milestone
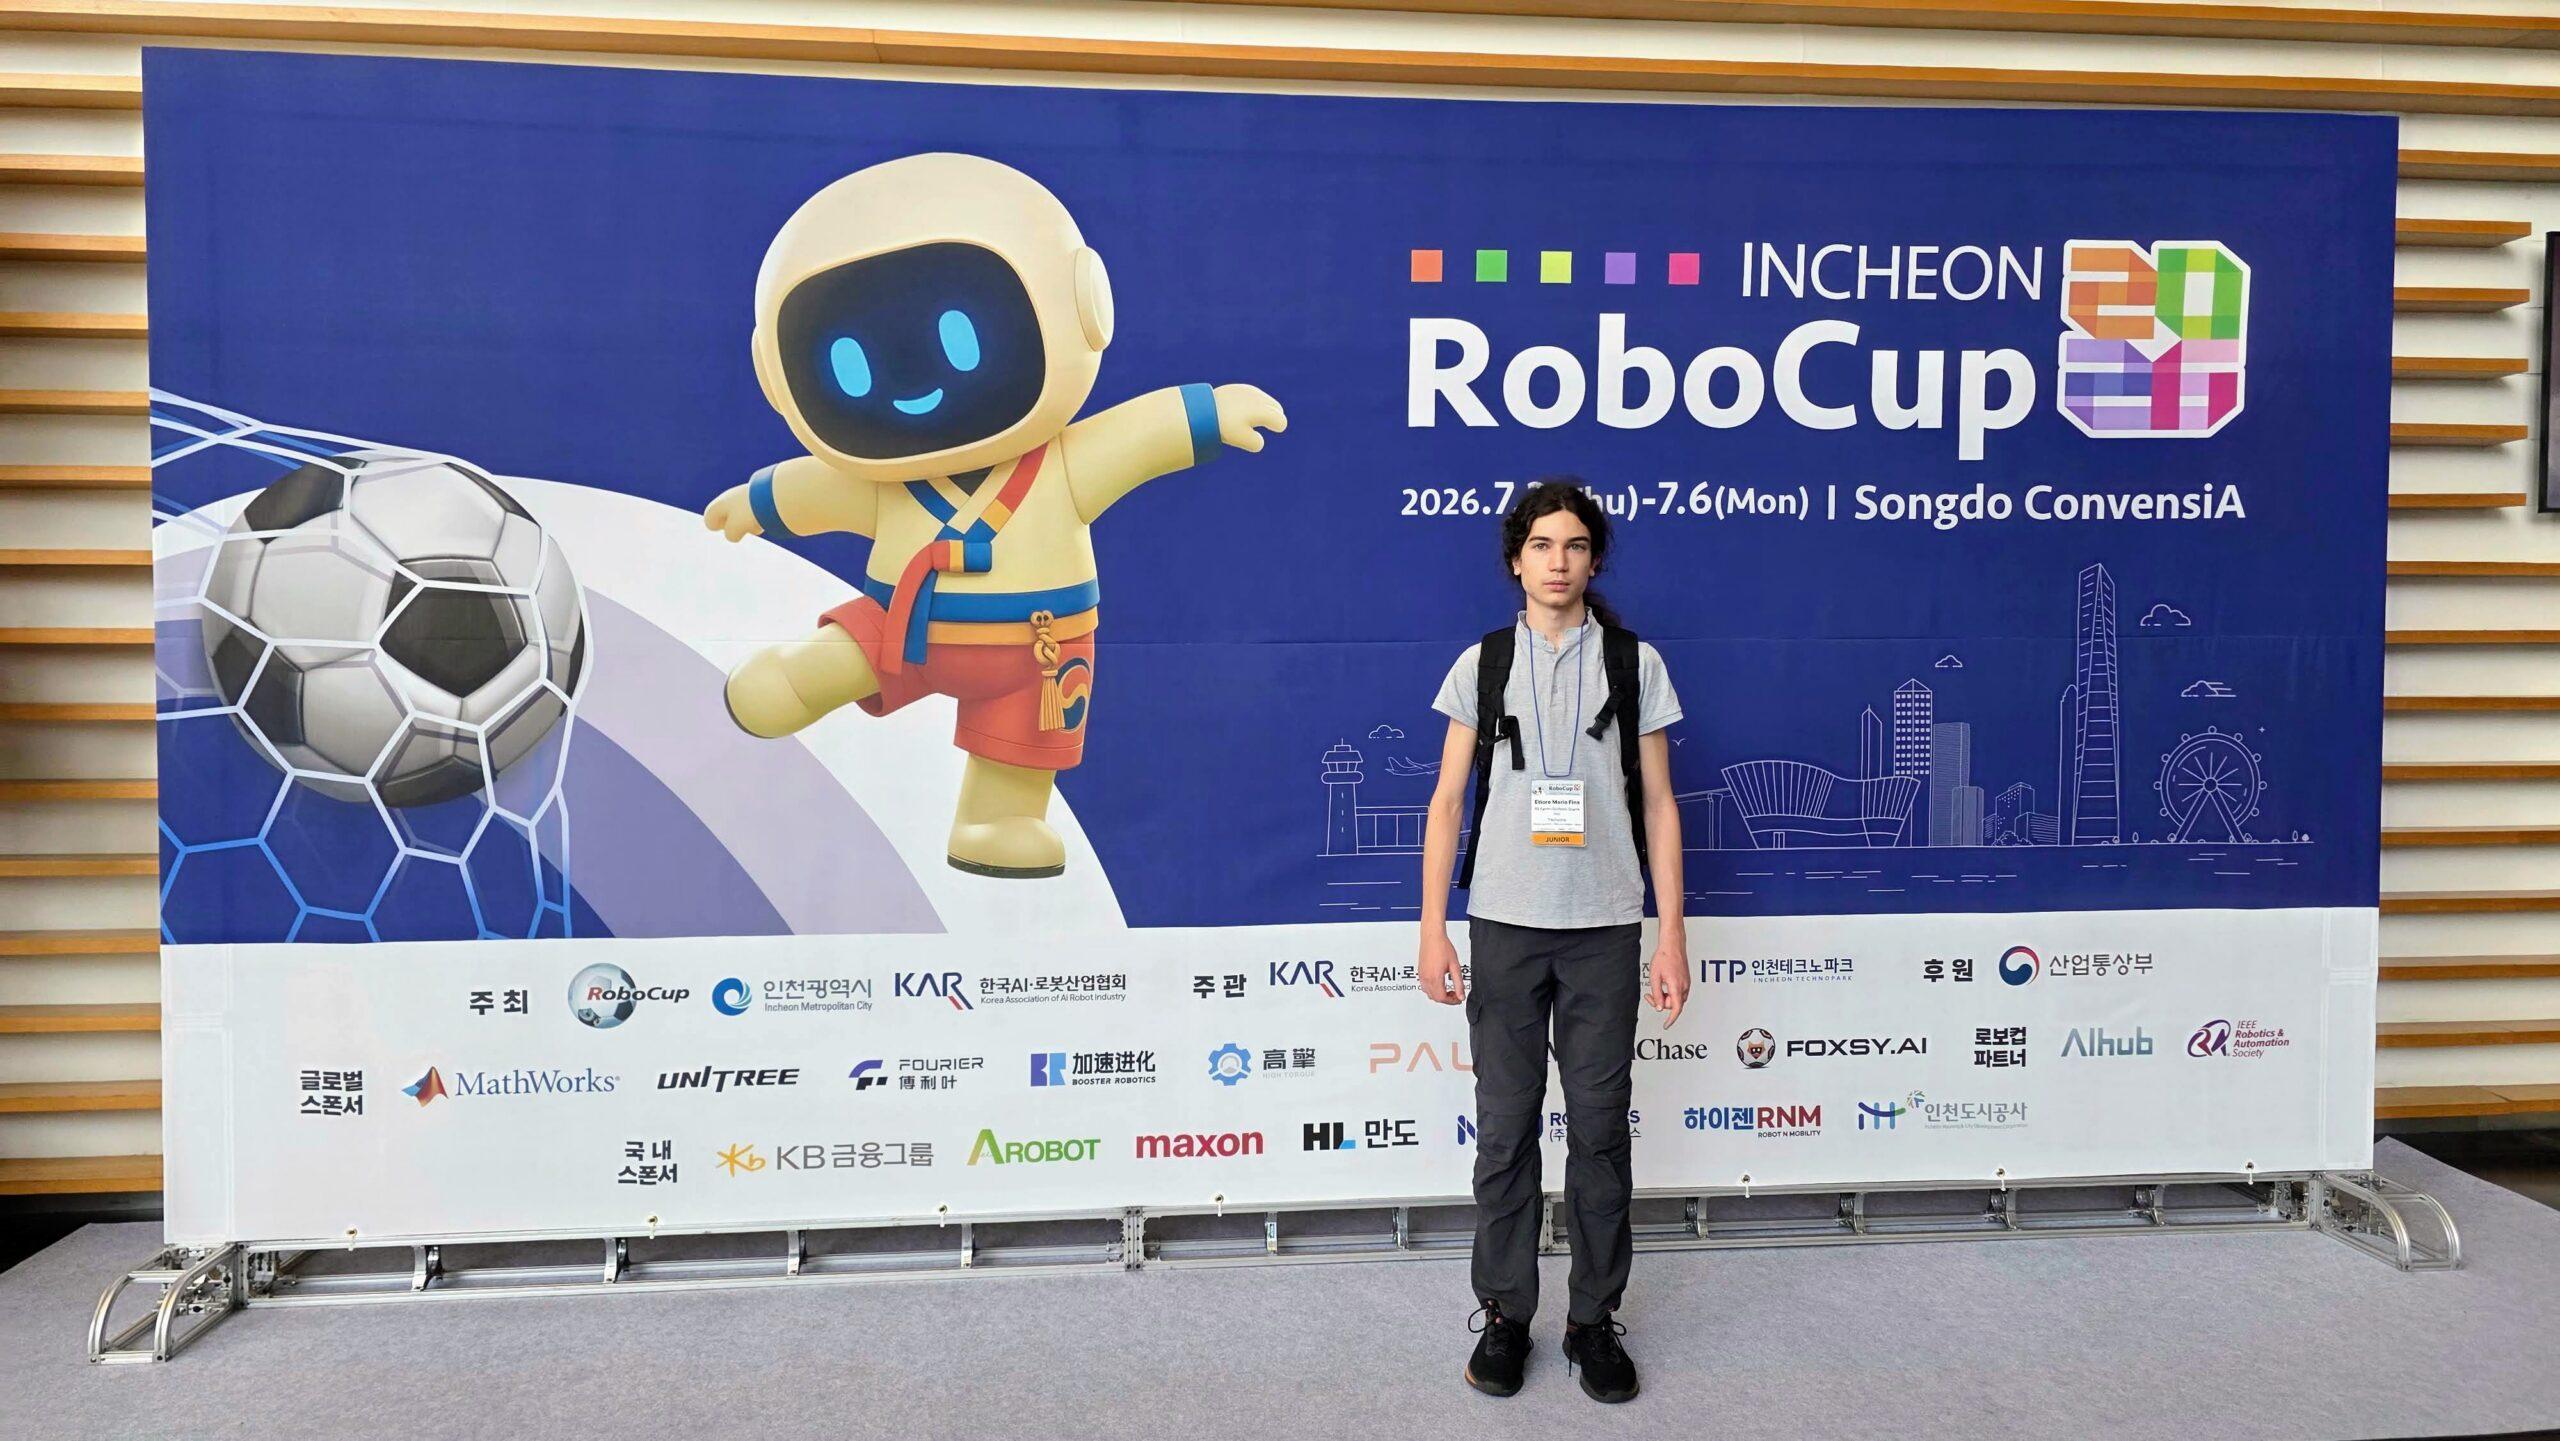
The 2026 season brought the new FermiLabs robotics direction to the World Championship, where the team finished in the global top ten. That result is important not only as a ranking, but as evidence of how much the team learned about reliability, preparation, debugging under pressure, field adaptation and the difference between a promising prototype and a robot that can complete a real maze.
What the robot taught us
- Safety and deterministic stop behaviour must remain local to the real-time controller.
- Sensor data need freshness, quality and calibration checks before they influence navigation.
- Mapping, localisation and mission state need explicit ownership and reproducible replay evidence.
- Camera and AI observations are valuable proposals, but they must not command motors directly.
- Competition software improves faster when every change follows the loop: model, build, measure, compare and improve.
Technologies and engineering connections
The current V2027-01 direction uses Arduino UNO Q and ArduinoCore-zephyr on the MCU side, with a Linux MPU for cameras, AI, datasets, replay, diagnostics and bench tools. The stack includes real-time distance, inertial and floor sensing, bounded motor control, 3D maze mapping, checkpoints, mission state and an explicit separation between Bench, Shadow and future Race authority.
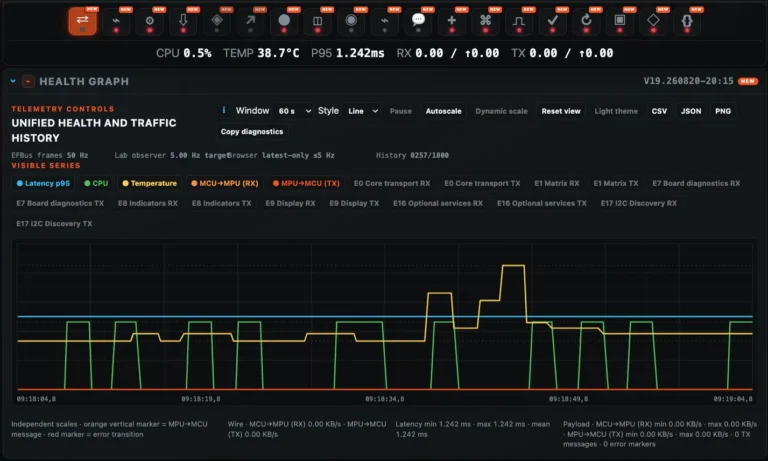
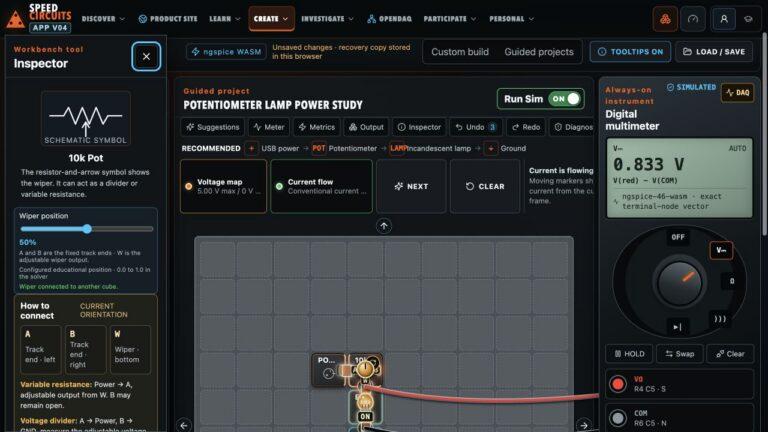
Our proprietary EFBus is the transport authority shared with the wider portfolio.OpenDAQprovides an optional read-only measurement path.SpeedCircuitscontributes the visual and timing-oriented engineering workflow, while FRC Studio represents the scientific-computing direction that can support simulation, geometry and evidence-driven comparison.
Next platform to evaluate: Arduino VENTUNO Q
If anArduino VENTUNO Qbecomes available to FermiLabs, we will begin a controlled experimentation and implementation phase before deciding whether it belongs in a competition robot. The official platform combines a Qualcomm Dragonwing IQ8 processor, with an octa-core Kryo CPU, Adreno 623 GPU and Hexagon AI acceleration up to 40 dense TOPS, with a dedicated STM32H5F5 Arm Cortex-M33 microcontroller running at 250 MHz for deterministic, low-latency control.
It also provides 16 GB of LPDDR5 memory, 64 GB of eMMC storage with an M.2 NVMe expansion path, Wi‑Fi 6, Bluetooth 5.3, 2.5 Gb Ethernet, camera and display interfaces, CAN-FD and Arduino App Lab support. For RoboCup, this dual-brain architecture could give us substantially more compute and memory headroom for computer vision, local AI, mapping, simulation and replay while keeping safety-critical motor and stop logic on the real-time MCU.
Our first VENTUNO Q work would therefore be experimental and measurable: benchmark perception latency, thermal and power behaviour, camera pipelines, sensor integration, mapping throughput, fault handling and the boundary between Linux-side proposals and MCU-side authority. Availability would not mean automatic adoption or competition compliance; any race use would still require a separate rules, hardware and safety qualification.
Autumn 2026 engineering update: Bench, EFBus10 and Robot-A25
The V2027-01 development line retains a single Arduino UNO Q architecture and distinct authority for MCU stop/motor safety, Linux-side perception, typed sensor records and the Bench/Shadow/Race validation ladder. The Robot-specific EFBus10 profile uses the192-bytetransport frame, API 1.10 / Wire 2.5 and separate Robot endpoint schema0x20270001.
The Robot-A25’s previously qualified operating SPI baseline remains3.2 MHz. A 50 MHz-capable host release and controlled higher-rate test tooling exist, but they must not be described as a successful 50 MHz physical Robot canary. The measured 50 MHz result belongs to the independent Muletto-18 EFBus EFC9 experiment.
Recent development covers TimeSync, source and epoch-aware telemetry, sensor freshness, motor diagnostics and replaceable motor modules. These milestones are evidence of engineering progress,not certification of a complete Race-ready robot; hardware, motors, cameras, tests and deployment have separate acceptance.
Related work:Arduino EFBusandArduino OpenDAQ.
Looking towards the 2027 edition
For 2027 we plan to consolidate the single-UNO-Q direction and, if a VENTUNO Q becomes available to us, evaluate the new platform as the next step in that architecture. We will validate the official rules and hardware requirements, strengthen the sensor and mapping pipeline, improve camera and AI replay evidence, and move from a Shadow-capable architecture towards a properly qualified Race profile. The next robot must be easier to diagnose, safer to stop, clearer to explain and more reproducible to rebuild than its predecessors.
Current status
The active application baseline isV2027-01. Host tests and software progress do not certify motors, sensors, cameras or complete-robot Race readiness. The 2026 Tachyons/QB8 work remains historical behavioural evidence; the 2027 implementation is a clean, modular continuation.
The technical repository remains the authority for exact source identity, safety constraints, competition requirements and qualification status. FermiLabs uses this page to connect the engineering history with the next public milestone.